Wheeled Robot Joint Selection Guide: 3KG & 5KG Schemes
On a wheeled robot, mobility is handled by the chassis, so joint selection centers on the upper-body joints. This article presents five EYOU wheeled robot joint selection schemes: PHU harmonic series 3KG, PHU harmonic 5KG (Scheme I and Scheme II), RHU harmonic series 3KG, and RHU harmonic 5KG. Each scheme lists machine-level specifications, the joint layout, and a per-model parameter table.
All five schemes share a 175 cm machine height and 20 degrees of freedom, with 3 kg and 5 kg arm payload classes. All joints run on 48 VDC (±10%) with EtherCAT / CANopen communication. PHU schemes target heavy-load industrial manufacturing; RHU schemes target light-load commercial use.
Five Wheeled Schemes at a Glance
| Scheme | Height | Weight | DOF | Max Arm Payload | Max Arm Joint Peak Torque | Max Leg Joint Peak Torque | Applications |
|---|---|---|---|---|---|---|---|
| PHU Harmonic 3KG Wheeled Robot Joint Selection Scheme | 175 cm | ≈120 kg | 20 | 3 kg | 86 N.m | 848 N.m | heavy-load industrial manufacturing |
| PHU Harmonic 5KG Wheeled Robot Joint Selection Scheme (I) | 175 cm | ≈150 kg | 20 | 5 kg | 182 N.m | 848 N.m | heavy-load industrial manufacturing |
| PHU Harmonic 5KG Wheeled Robot Joint Selection Scheme (II) | 175 cm | ≈160 kg | 20 | 5 kg | 182 N.m | 1458 N.m | heavy-load industrial manufacturing |
| RHU Harmonic 3KG Wheeled Robot Joint Selection Scheme | 175 cm | ≈120 kg | 20 | 3 kg | 89 N.m | 848 N.m | light-load commercial use |
| RHU Harmonic 5KG Wheeled Robot Joint Selection Scheme | 175 cm | ≈150 kg | 20 | 5 kg | 184 N.m | 848 N.m | light-load commercial use |
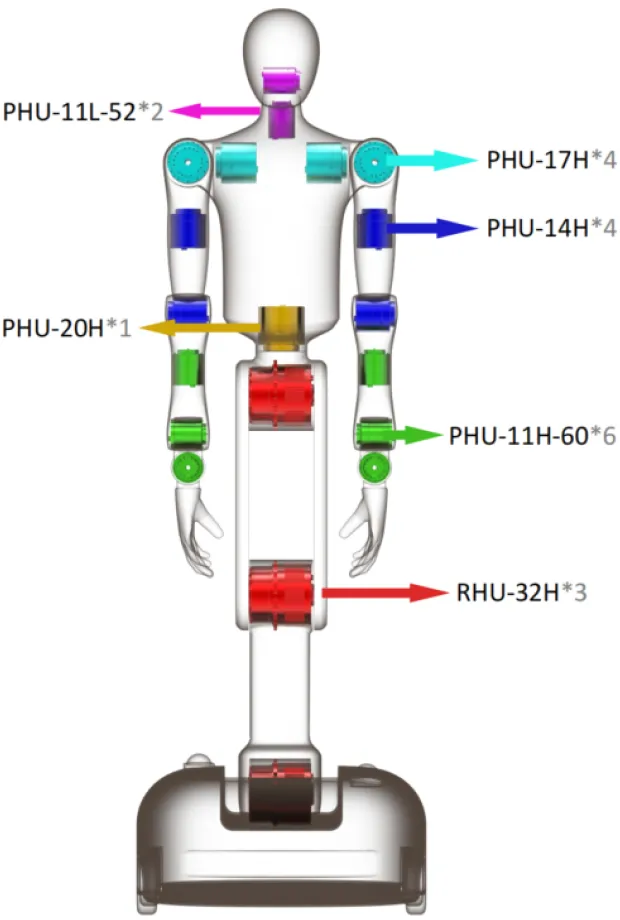
PHU Harmonic 3KG Wheeled Robot Joint Selection Scheme
Machine height 175 cm, weight ≈120 kg, 20 DOF, max arm payload 3 kg, max arm joint peak torque 86 N.m, max leg joint peak torque 848 N.m. Applications: heavy-load industrial manufacturing.
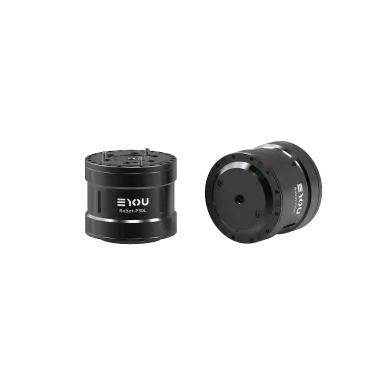
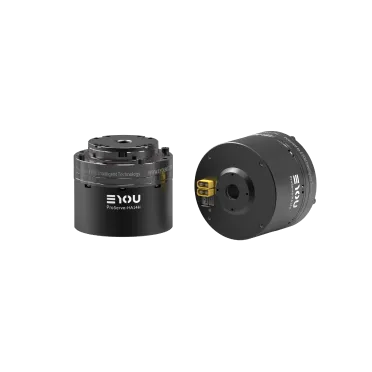
Joint layout: PHU-11L-52 ×2, PHU-11H-60 ×6, PHU-14H ×4, PHU-17H ×4, PHU-20H ×1, RHU-32H ×3 — 20 joints in total.
| Parameter | PHU-11L-52 | PHU-11H-60 | PHU-14H | PHU-17H | PHU-20H | RHU-32H | |||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 51 | 101 | 51 | 101 | 51 | 101 | 51 | 101 | 81 | 101 | 121 | 120 | 160 | |
| Reducer Type | Harmonic Reducer | ||||||||||||
| Rated Torque (N.m) | 3.5 | 5.5 | 5.5 | 8.9 | 8.6 | 13.5 | 32 | 49 | 58 | 61 | 61 | 197 | 267 |
| Peak Torque (N.m) | 11.5 | 15 | 17 | 25 | 43 | 66 | 86 | 134 | 158 | 182 | 182 | 848 | 848 |
| Rated Power (W) | 10 | 6 | 14 | 10 | 27 | 20 | 81 | 62 | 109 | 104 | 87 | 216 | 221 |
| Rated Output Speed (rpm) | 39 | 20 | 39 | 20 | 39 | 20 | 39 | 20 | 25 | 20 | 17 | 17 | 12.5 |
| Peak Output Speed (rpm) | 100 | 50 | 100 | 50 | 90 | 45 | 88 | 44 | 38 | 31 | 25 | 22 | 16.25 |
| Dimensions (OD x Length, mm) | Φ52 x 65 | Φ60 x 68.5 | Φ70 x 75.4 | Φ80 x 78 | Φ90 x 85.8 | Φ120*126 | |||||||
| Weight (kg, B/N) | 0.39 / 0.35 | 0.59 / 0.54 | 0.89 / 0.81 | 1.25 / 1.14 | 1.74 / 1.58 | 4.36/4.08 | |||||||
| Hollow Bore Diameter (mm) | 8 | 8 | 10.8 | 10.8 | 13 | 22 | |||||||
| Output Radial Load (Dynamic/Static, N) | 130 | 130 | 270 | 400 | 650 | 1350 | |||||||
| Output Axial Load (Dynamic/Static, N) | 130 | 130 | 270 | 400 | 650 | 1350 | |||||||
| Operating Voltage (VDC) | 48 ± 10% | ||||||||||||
| Communication Protocol | EtherCAT / CANopen | ||||||||||||
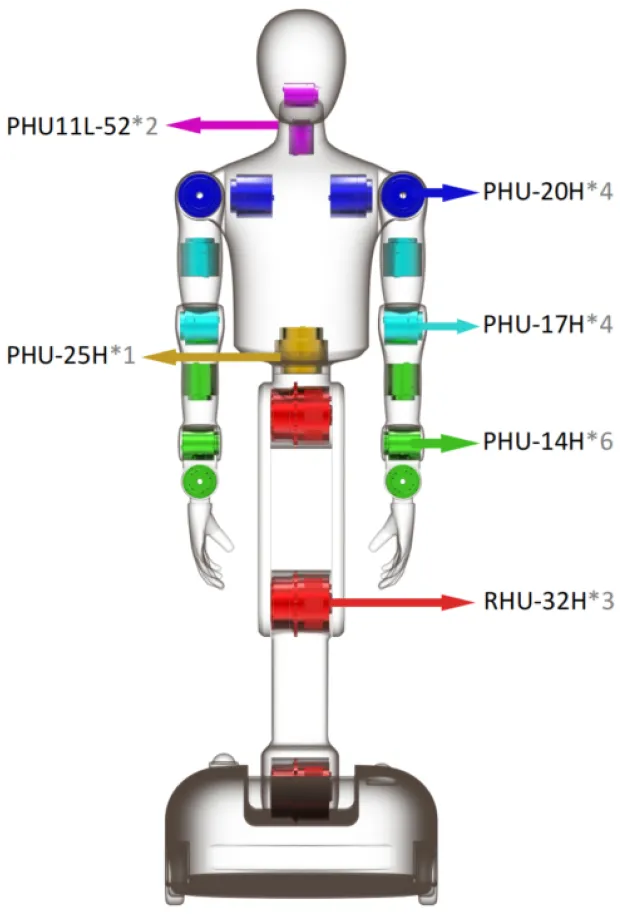
PHU Harmonic 5KG Wheeled Robot Joint Selection Scheme (I)
Machine height 175 cm, weight ≈150 kg, 20 DOF, max arm payload 5 kg, max arm joint peak torque 182 N.m, max leg joint peak torque 848 N.m. Applications: heavy-load industrial manufacturing.
Joint layout: PHU-14H ×6, PHU-20H ×4, PHU-17H ×4, PHU-11L-52 ×2, PHU-25H ×1, RHU-32H ×3 — 20 joints in total.
| Parameter | PHU-11L-52 | PHU-14H | PHU-17H | PHU-20H | PHU-25H | RHU-32H | ||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 51 | 101 | 51 | 101 | 51 | 101 | 81 | 101 | 121 | 81 | 101 | 121 | 120 | 160 | |
| Reducer Type | Harmonic Reducer | |||||||||||||
| Rated Torque (N.m) | 3.5 | 5.5 | 8.6 | 13.5 | 32 | 49 | 58 | 61 | 61 | 107 | 133 | 133 | 197 | 267 |
| Peak Torque (N.m) | 11.5 | 15 | 43 | 66 | 86 | 134 | 158 | 182 | 182 | 315 | 351 | 376 | 848 | 848 |
| Rated Power (W) | 10 | 6 | 27 | 20 | 81 | 62 | 109 | 104 | 87 | 202 | 174 | 145 | 216 | 221 |
| Rated Output Speed (rpm) | 39 | 20 | 39 | 20 | 39 | 20 | 25 | 20 | 17 | 25 | 20 | 17 | 17 | 12.5 |
| Peak Output Speed (rpm) | 100 | 50 | 90 | 45 | 88 | 44 | 38 | 31 | 25 | 44 | 36 | 30 | 22 | 16.25 |
| Dimensions (OD x Length, mm) | Φ52 x 65 | Φ70 x 75.4 | Φ80 x 78 | Φ90 x 85.8 | Φ110 x 94 | Φ120*126 | ||||||||
| Weight (kg, B/N) | 0.39 / 0.35 | 0.89 / 0.81 | 1.25 / 1.14 | 1.74 / 1.58 | 2.54 / 2.35 | 4.36/4.08 | ||||||||
| Hollow Bore Diameter (mm) | 8 | 10.8 | 10.8 | 13 | 13 | 22 | ||||||||
| Output Radial Load (Dynamic/Static, N) | 130 | 270 | 400 | 650 | 900 | 1350 | ||||||||
| Output Axial Load (Dynamic/Static, N) | 130 | 270 | 400 | 650 | 900 | 1350 | ||||||||
| Operating Voltage (VDC) | 48 ± 10% | |||||||||||||
| Communication Protocol | EtherCAT / CANopen | |||||||||||||
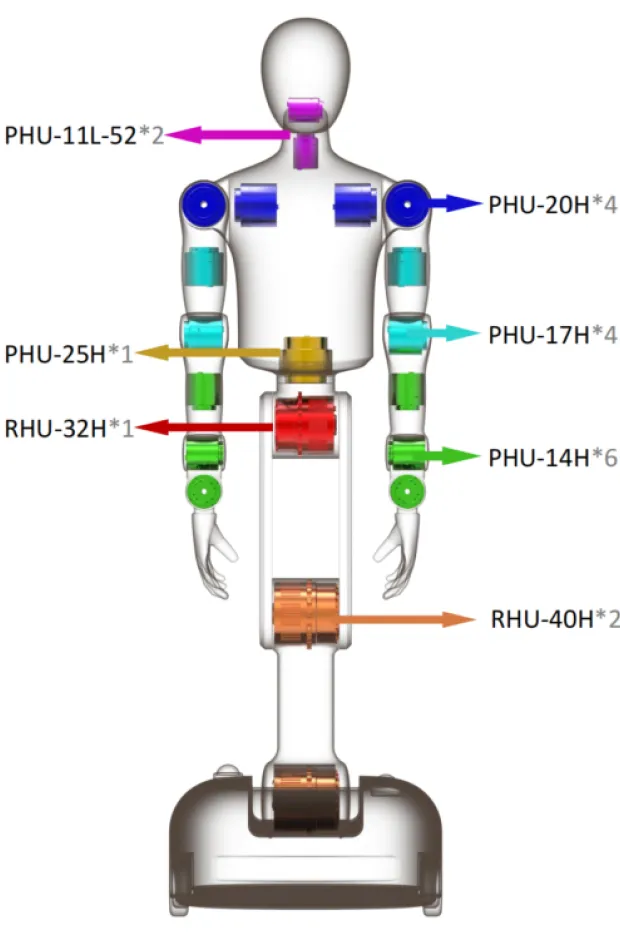
PHU Harmonic 5KG Wheeled Robot Joint Selection Scheme (II)
Machine height 175 cm, weight ≈160 kg, 20 DOF, max arm payload 5 kg, max arm joint peak torque 182 N.m, max leg joint peak torque 1458 N.m. Applications: heavy-load industrial manufacturing.
Joint layout: PHU-14H ×6, PHU-20H ×4, PHU-17H ×4, PHU-11L-52 ×2, PHU-25H ×1, RHU-32H ×1, RHU-40H ×2 — 20 joints in total.
| Parameter | PHU-11L-52 | PHU-14H | PHU-17H | PHU-20H | PHU-25H | RHU-32H | RHU-40H | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 51 | 101 | 51 | 101 | 51 | 101 | 81 | 101 | 121 | 81 | 101 | 121 | 120 | 160 | 120 | 160 | |
| Reducer Type | Harmonic Reducer | |||||||||||||||
| Rated Torque (N.m) | 3.5 | 5.5 | 8.6 | 13.5 | 32 | 49 | 58 | 61 | 61 | 107 | 133 | 133 | 197 | 267 | 248 | 363 |
| Peak Torque (N.m) | 11.5 | 15 | 43 | 66 | 86 | 134 | 158 | 182 | 182 | 315 | 351 | 376 | 848 | 848 | 1458 | 1458 |
| Rated Power (W) | 10 | 6 | 27 | 20 | 81 | 62 | 109 | 104 | 87 | 202 | 174 | 145 | 216 | 221 | 433 | 475 |
| Rated Output Speed (rpm) | 39 | 20 | 39 | 20 | 39 | 20 | 25 | 20 | 17 | 25 | 20 | 17 | 17 | 12.5 | 17 | 12.5 |
| Peak Output Speed (rpm) | 100 | 50 | 90 | 45 | 88 | 44 | 38 | 31 | 25 | 44 | 36 | 30 | 22 | 16.25 | 22 | 16.25 |
| Dimensions (OD x Length, mm) | Φ52 x 65 | Φ70 x 75.4 | Φ80 x 78 | Φ90 x 85.8 | Φ110 x 94 | Φ120*126 | Φ130*136 | |||||||||
| Weight (kg, B/N) | 0.39 / 0.35 | 0.89 / 0.81 | 1.25 / 1.14 | 1.74 / 1.58 | 2.54 / 2.35 | 4.36/4.08 | 6.15/5.82 | |||||||||
| Hollow Bore Diameter (mm) | 8 | 10.8 | 10.8 | 13 | 13 | 22 | 22 | |||||||||
| Output Radial Load (Dynamic/Static, N) | 130 | 270 | 400 | 650 | 900 | 1350 | 2000 | |||||||||
| Output Axial Load (Dynamic/Static, N) | 130 | 270 | 400 | 650 | 900 | 1350 | 2000 | |||||||||
| Operating Voltage (VDC) | 48 ± 10% | |||||||||||||||
| Communication Protocol | EtherCAT / CANopen | |||||||||||||||
RHU Harmonic 3KG Wheeled Robot Joint Selection Scheme
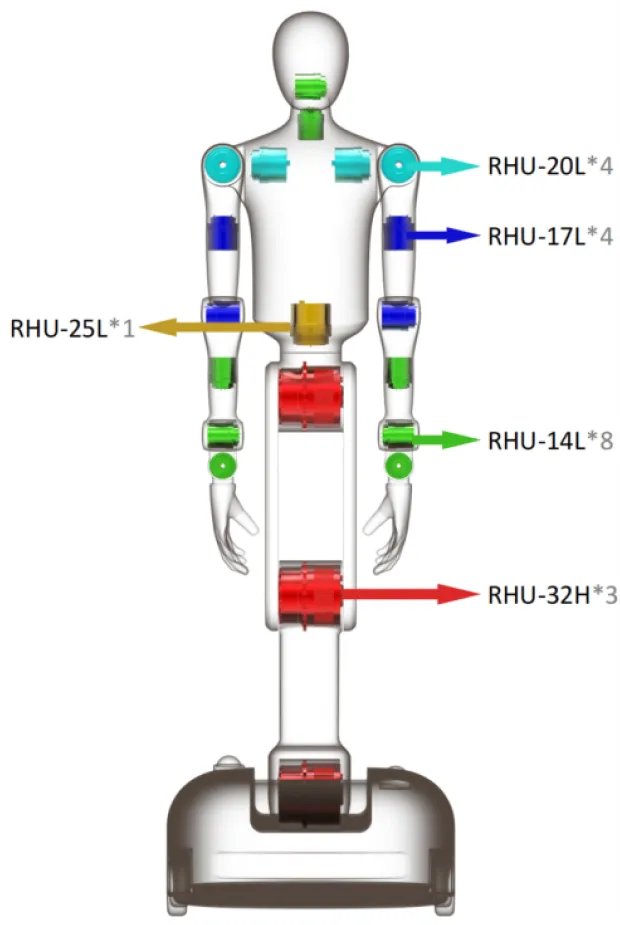
Machine height 175 cm, weight ≈120 kg, 20 DOF, max arm payload 3 kg, max arm joint peak torque 89 N.m, max leg joint peak torque 848 N.m. Applications: light-load commercial use.
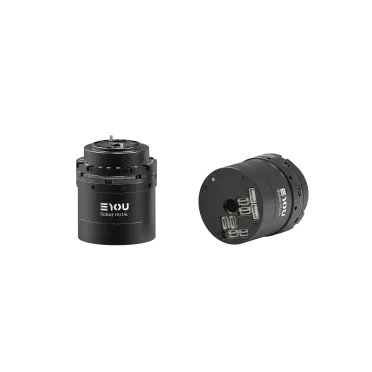
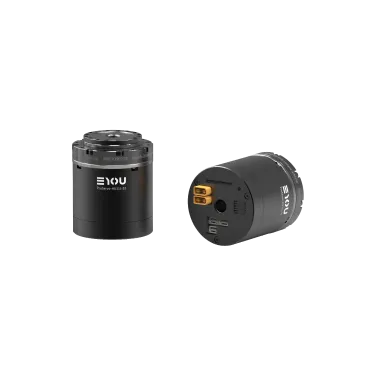
Joint layout: RHU-14L ×8, RHU-17L ×4, RHU-20L ×4, RHU-25L ×1, RHU-32H ×3 — 20 joints in total.
| Parameter | RHU-14L | RHU-17L | RHU-20L | RHU-25L | RHU-32H | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 50 | 80 | 100 | 50 | 80 | 100 | 50 | 80 | 100 | 50 | 80 | 100 | 120 | 160 | |
| Reducer Type | Harmonic Reducer | |||||||||||||
| Rated Torque (N.m) | 4.8 | 7.7 | 7.7 | 18 | 19 | 27 | 24 | 33 | 34 | 38 | 60 | 75 | 197 | 267 |
| Peak Torque (N.m) | 24 | 35 | 35 | 48 | 61 | 71 | 69 | 89 | 95 | 127 | 179 | 184 | 848 | 848 |
| Rated Power (W) | 15 | 14 | 11 | 46 | 39 | 34 | 71 | 63 | 59 | 113 | 115 | 98 | 216 | 221 |
| Rated Output Speed (rpm) | 40 | 25 | 20 | 40 | 25 | 20 | 40 | 25 | 20 | 40 | 25 | 20 | 17 | 12.5 |
| Peak Output Speed (rpm) | 99 | 62.5 | 50 | 79 | 50 | 40 | 79 | 50 | 40 | 79 | 50 | 40 | 22 | 16.25 |
| Dimensions (OD x Length, mm) | Φ52 x 65 | Φ60 x 66 | Φ70 x 68 | Φ80*80.5 | Φ120*126 | |||||||||
| Weight (kg, B/N) | 0.397 / 0.382 | 0.538 / 0.521 | 0.832 / 0.811 | 1.294/1.266 | 4.36/4.08 | |||||||||
| Hollow Bore Diameter (mm) | 8 | 10 | 13 | 18 | 22 | |||||||||
| Output Radial Load (Dynamic/Static, N) | 180 | 230 | 270 | 440 | 1350 | |||||||||
| Output Axial Load (Dynamic/Static, N) | 180 | 230 | 270 | 440 | 1350 | |||||||||
| Operating Voltage (VDC) | 48 ± 10% | |||||||||||||
| Communication Protocol | EtherCAT / CANopen | |||||||||||||
RHU Harmonic 5KG Wheeled Robot Joint Selection Scheme
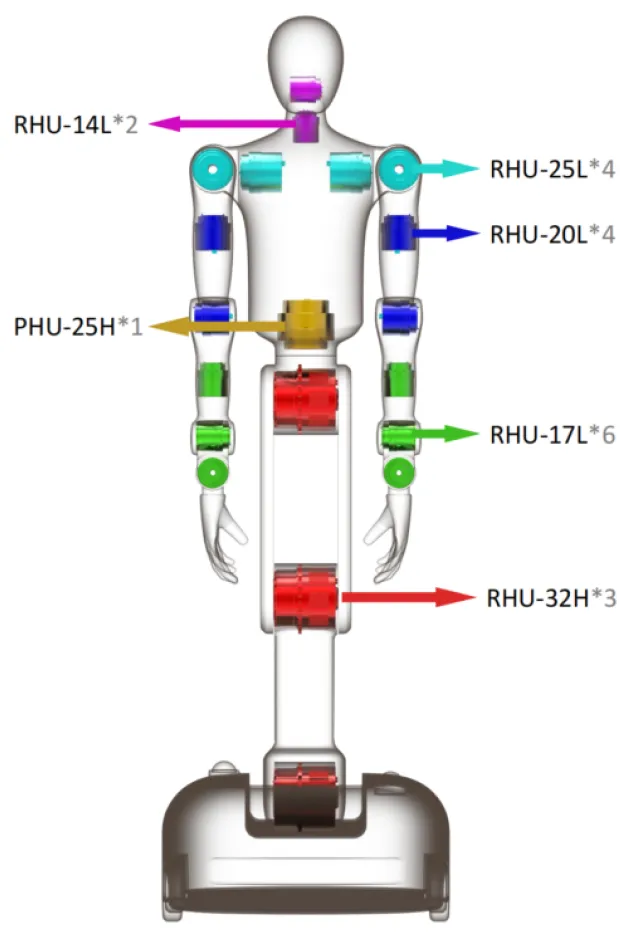
Machine height 175 cm, weight ≈150 kg, 20 DOF, max arm payload 5 kg, max arm joint peak torque 184 N.m, max leg joint peak torque 848 N.m. Applications: light-load commercial use.
Joint layout: RHU-17L ×6, RHU-20L ×4, RHU-25L ×4, RHU-14L ×2, PHU-25H ×1, RHU-32H ×3 — 20 joints in total.
| Parameter | RHU-14L | RHU-17L | RHU-20L | RHU-25L | PHU-25H | RHU-32H | |||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 50 | 80 | 100 | 50 | 80 | 100 | 50 | 80 | 100 | 50 | 80 | 100 | 81 | 101 | 121 | 120 | 160 | |
| Reducer Type | Harmonic Reducer | ||||||||||||||||
| Rated Torque (N.m) | 4.8 | 7.7 | 7.7 | 18 | 19 | 27 | 24 | 33 | 34 | 38 | 60 | 75 | 107 | 133 | 133 | 197 | 267 |
| Peak Torque (N.m) | 24 | 35 | 35 | 48 | 61 | 71 | 69 | 89 | 95 | 127 | 179 | 184 | 315 | 351 | 376 | 848 | 848 |
| Rated Power (W) | 15 | 14 | 11 | 46 | 39 | 34 | 71 | 63 | 59 | 113 | 115 | 98 | 202 | 174 | 145 | 216 | 221 |
| Rated Output Speed (rpm) | 40 | 25 | 20 | 40 | 25 | 20 | 40 | 25 | 20 | 40 | 25 | 20 | 25 | 20 | 17 | 17 | 12.5 |
| Peak Output Speed (rpm) | 99 | 62.5 | 50 | 79 | 50 | 40 | 79 | 50 | 40 | 79 | 50 | 40 | 44 | 36 | 30 | 22 | 16.25 |
| Dimensions (OD x Length, mm) | Φ52 x 65 | Φ60 x 66 | Φ70 x 68 | Φ80*80.5 | Φ110 x 94 | Φ120*126 | |||||||||||
| Weight (kg, B/N) | 0.397 / 0.382 | 0.538 / 0.521 | 0.832 / 0.811 | 1.294/1.266 | 2.54 / 2.35 | 4.36/4.08 | |||||||||||
| Hollow Bore Diameter (mm) | 8 | 10 | 13 | 18 | 13 | 22 | |||||||||||
| Output Radial Load (Dynamic/Static, N) | 180 | 230 | 270 | 440 | 900 | 1350 | |||||||||||
| Output Axial Load (Dynamic/Static, N) | 180 | 230 | 270 | 440 | 900 | 1350 | |||||||||||
| Operating Voltage (VDC) | 48 ± 10% | ||||||||||||||||
| Communication Protocol | EtherCAT / CANopen | ||||||||||||||||
Related Series and Solutions
Series pages: PHU Enhanced Harmonic Drive Robot Actuator, RHU Humanoid Harmonic Drive Robot Actuator; solution page: Full-Size Humanoid Robot Joint Actuator Solution.
FAQ
All five wheeled schemes have 20 degrees of freedom, i.e. 20 joint actuators per machine. The 3KG and 5KG schemes differ in model mix and torque class, not in joint count.
Four schemes — PHU 3KG, PHU 5KG Scheme I, RHU 3KG, and RHU 5KG — reach 848 N.m with the RHU-32H. The PHU 5KG Scheme II uses the RHU-40H and reaches 1458 N.m.
PHU harmonic wheeled schemes target heavy-load industrial manufacturing, while RHU harmonic wheeled schemes target light-load commercial use. Both run on 48 VDC (±10%) with EtherCAT / CANopen.
PHU 3KG and RHU 3KG are about 120 kg, PHU 5KG Scheme I and RHU 5KG are about 150 kg, and PHU 5KG Scheme II is about 160 kg. All five schemes are 175 cm tall.
All joints in the five schemes use 48 VDC (±10%) power and EtherCAT / CANopen communication.